





MANTIS Dexterous Morphing Robot
One control brain, six quick-mount forms: arm, engineering, chassis, dual-arm, inspection and complete. Change the form the task needs instead of buying a second robot.
Look and see


- Briefly describe: One control brain, six quick-mount forms: arm, engineering, chassis, dual-arm, inspection and complete. Change the form the task needs instead of buying a second robot.
- Product Model: MANTIS
One brain, many forms
MANTIS is a modular dual-arm mobile manipulation platform. The same controller adapts to several physical forms; modules connect mechanically and electrically through quick-mount interfaces — from a single arm and a wheeled base to dual arms and the complete robot — assembled around the task at hand.
Six forms, one platform
From a standalone manipulation unit to a complete mobile manipulation robot: the structure adapts to the task, instead of the task being forced into one fixed shape. Choose the form you need today and re-combine the same modules when the requirement changes.
- Arm form — independent single-arm module, a standalone manipulation unit.
- Engineering form — engineering configuration built from the same module set.
- Chassis form — omnidirectional mobile base that carries the platform.
- Dual-arm form — dual-arm configuration for manipulation and coordinated tasks.
- Inspection form — inspection configuration for patrol and survey rounds.
- Complete form — full robot: vision head, dual arms, lift mechanism and wheeled base.
Product structure
- Robot body — main body and functional modules use a composable structure.
- Dual arms — dual-arm configuration for manipulation and coordinated tasks.
- Wheeled base — handles mobility and forms the working envelope together with the lift.
- Lift mechanism — extends the vertical task range.
- Vision head — perception hardware; the sensor set depends on configuration.
- Hand quick-change — interface for swapping end effectors.
- Development interface — ROS 2, SDK and simulation tools for secondary development.
Core specifications — complete form
| Dimensions (L × W × H) | 633 × 552 × 1400 mm |
|---|---|
| Lift range | 550 mm |
| Whole-body degrees of freedom | 22 |
| Control latency | < 10 ms |
| Forward speed | 3 m/s |
| Lift speed | 200 mm/s |
| Base | 3-DOF omnidirectional |
| Battery life (complete robot) | 3 h |
| Upper arm / forearm | 250 mm / 260 mm |
| Arm span | 663 mm |
| Single-arm payload | 7 kg |
Find the configuration that fits your task
Start with the module, then compare.
Every capability maps to a specific version.
Arm configuration
Start from a standalone manipulation unit. Compare payload, control hardware and development support to pick the arm that fits the task.
Images show the form only, not the full equipment set of every version.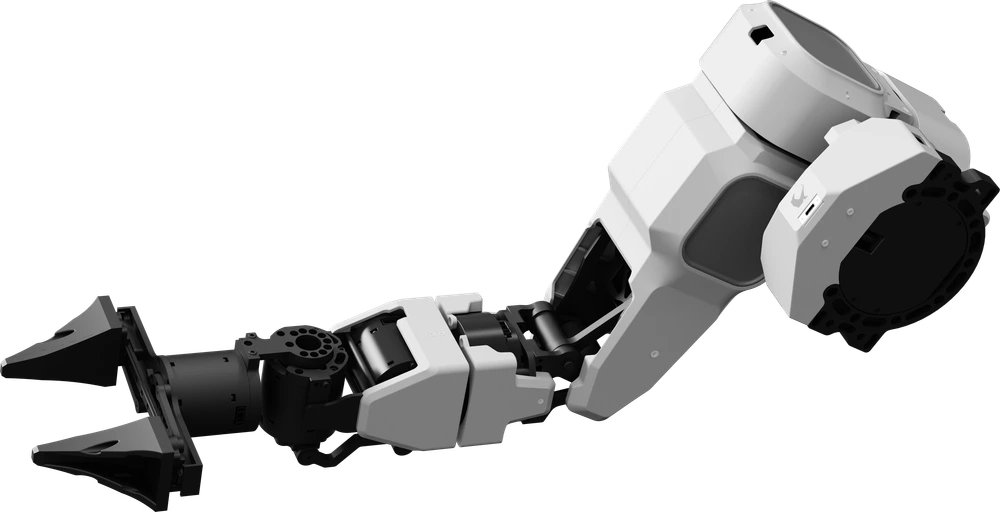
| Configuration | Arm (Youth) | Arm |
|---|---|---|
| Payload | 3 kg per arm | 7 kg per arm |
| Arm DOF | 7 DOF | 7 + 1 DOF |
| Max motor torque | 80 N·m | 120 N·m |
| Communication & data interfaces | USB 2.0, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 |
| Compute | Domain controller | Domain controller + NUC |
| Simulation environment | — | ✓ |
| ROS 2 / MoveIt 2 / SDK | — | ✓ |
| VR teleoperation | — | ✓ |
| Depth camera | — | — |
| Secondary development | — | ✓ |
| Warranty | 3 months | 6 months + dedicated service |
Figures describe the selected module. “Dedicated service” keeps the original wording — ask sales for the exact scope.
Chassis configuration
3-DOF omnidirectional mobility. Standalone chassis figures and complete-robot performance are quoted separately, so speed and battery numbers are never mixed.
Images show the form only, not the full equipment set of every version.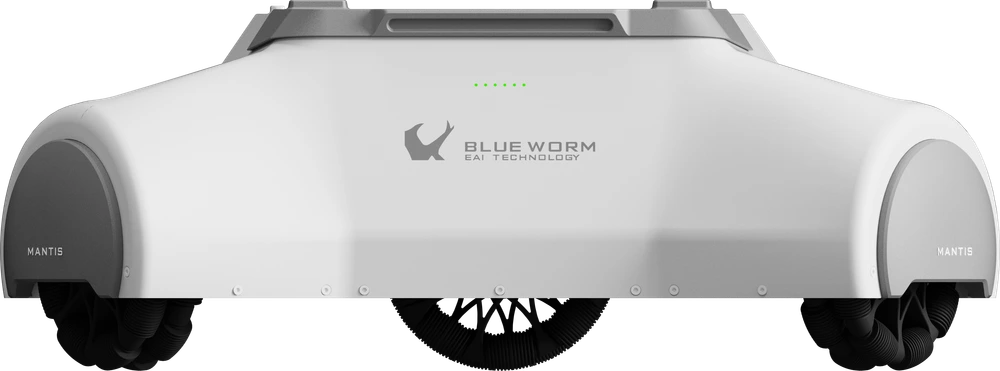
| Configuration | Chassis (Youth) | Chassis |
|---|---|---|
| Payload | 60 kg | 60 kg |
| Mobility | 3-DOF omnidirectional | 3-DOF omnidirectional |
| Travel speed | 5 m/s | 5 m/s |
| Communication & data interfaces | USB 2.0, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 |
| Compute | Domain controller | Domain controller + NUC |
| Battery life | 6 h | 6 h |
| ROS 2 / MoveIt 2 / SDK | — | ✓ |
| VR teleoperation | — | ✓ |
| LiDAR | — | ✓ |
| Secondary development | ✓ | ✓ |
| Warranty | 6 months + dedicated service | 1 year + dedicated service |
Chassis speed and battery are measured on the standalone module. “Dedicated service” keeps the original wording — ask sales for the exact scope.
Dual-arm configuration
Built for dual-arm manipulation and coordinated tasks. The four versions differ in compute, perception and development tooling.
Images show the form only, not the full equipment set of every version.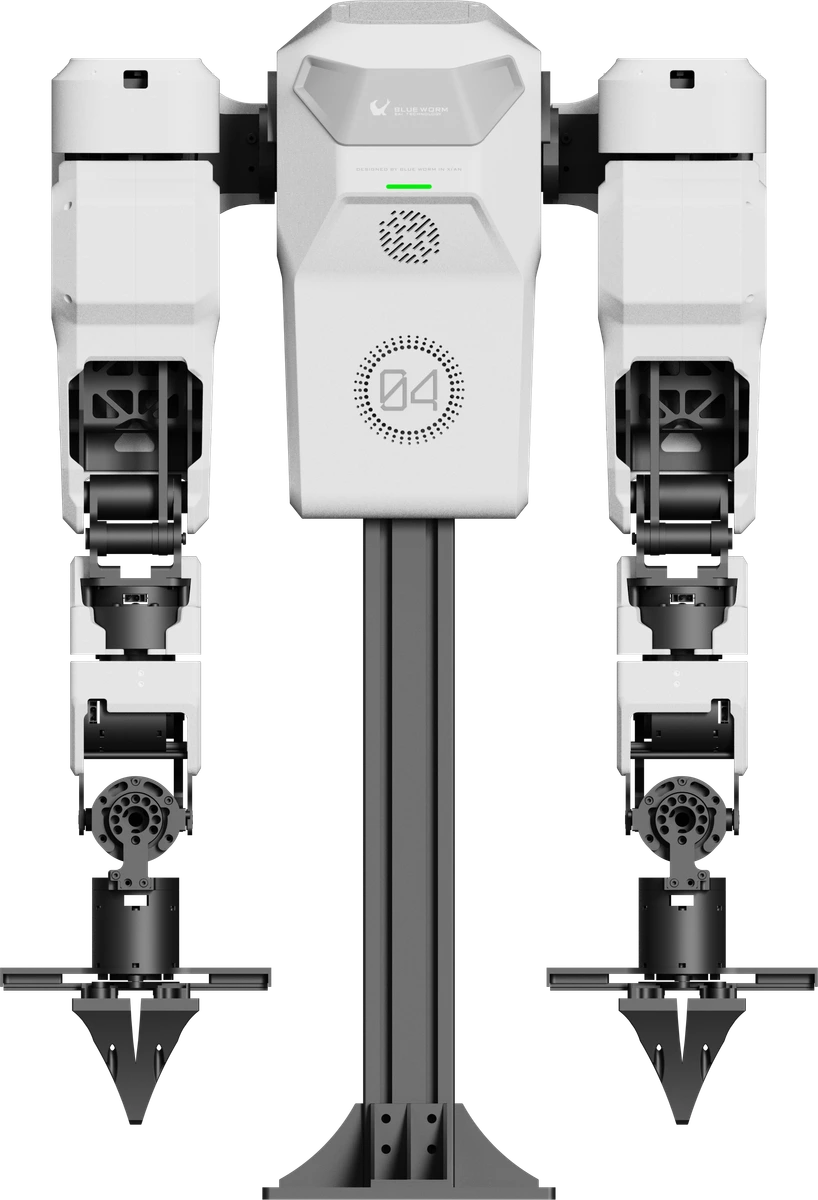
| Configuration | Dual-arm (Entry) | Dual-arm (Advanced) | Dual-arm (Deluxe) | Dual-arm (Flagship) |
|---|---|---|---|---|
| Payload | 3 kg per arm / 6 kg dual | 7 kg per arm / 14 kg dual | 7 kg per arm / 14 kg dual | 7 kg per arm / 14 kg dual |
| Max motor torque | 80 N·m | 120 N·m | 120 N·m | 120 N·m |
| Communication & data interfaces | USB 2.0, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 |
| Compute | Domain controller | Domain controller + NUC | Domain controller + NUC | Domain controller + NUC |
| Simulation environment | — | ✓ | ✓ | ✓ |
| ROS 2 / MoveIt 2 / SDK | — | ✓ | ✓ | ✓ |
| VR teleoperation | — | — | ✓ | ✓ |
| PICO teleoperation kit | — | — | ✓ | ✓ |
| VLA routines | — | — | — | ✓ |
| Depth camera | — | — | Head camera × 1 | Head camera × 1 / wrist cameras × 2 |
| Secondary development | — | ✓ | ✓ | ✓ |
| Warranty | 3 months | 6 months + dedicated service | 1 year + dedicated service | 1 year + dedicated service |
Perception items are listed per version. “Dedicated service” keeps the original wording — ask sales for the exact scope.
Complete robot configuration
Mobility, dual arms, lift and perception as one robot. DOF, sensors and development support follow the column of each version.
Images show the form only, not the full equipment set of every version.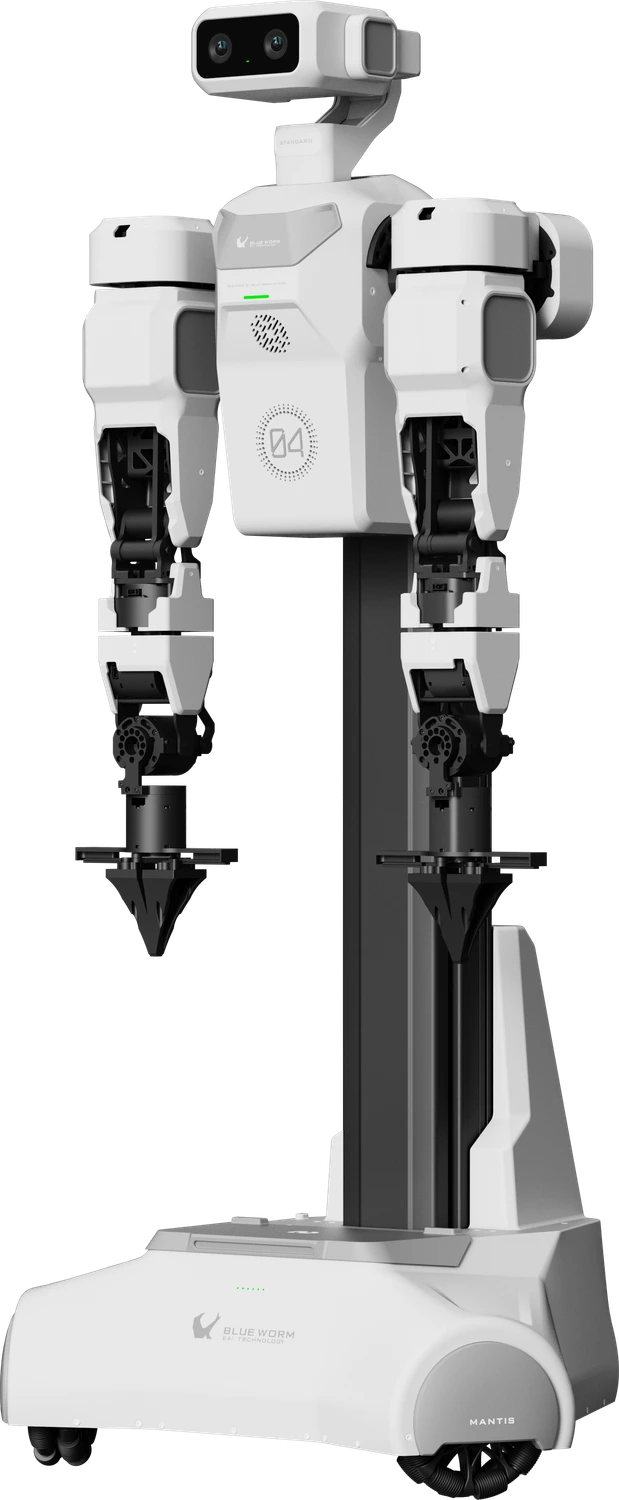
| Configuration | Complete (Entry) | Complete (DIY) | Complete (Guide) | Complete (Research) | Complete (Flagship) |
|---|---|---|---|---|---|
| Payload | 3 kg per arm / 6 kg dual | 7 kg per arm / 14 kg dual | 7 kg per arm / 14 kg dual | 7 kg per arm / 14 kg dual | 7 kg per arm / 14 kg dual |
| Mobility | 3-DOF omnidirectional | 3-DOF omnidirectional | 3-DOF omnidirectional | 3-DOF omnidirectional | 3-DOF omnidirectional |
| Lift | Fixed bracket | Auto lift | Auto lift | Auto lift | Auto lift |
| Whole-body DOF | Arms 14 / base 3 | Arms 16 / base 3 / waist 1 | Arms 16 / base 3 / head 2 / waist 1 | Arms 16 / base 3 / waist 1 | Arms 16 / base 3 / head 2 / waist 1 |
| Max motor torque | 80 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m |
| Communication & data interfaces | USB 2.0, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 | Wi-Fi 6, Bluetooth 5.0, USB 3.1, CAN 2.0 |
| Compute | Domain controller | Domain controller + NUC | Domain controller + NUC | Domain controller + NUC | Domain controller + NUC |
| Battery life | 3 h | 3 h | 3 h | 3 h | 3 h |
| Simulation environment | — | ✓ | ✓ | ✓ | ✓ |
| ROS 2 / MoveIt 2 / SDK | — | ✓ | ✓ | ✓ | ✓ |
| VR teleoperation | — | — | ✓ | ✓ | ✓ |
| LiDAR | — | — | ✓ | ✓ | ✓ |
| PICO teleoperation kit | — | — | ✓ | ✓ | ✓ |
| VLA routines | — | — | — | ✓ | ✓ |
| Depth camera / stereo vision | — | — | Stereo vision | Head camera × 1 / wrist cameras × 2 | Stereo vision / head camera × 1 / wrist cameras × 2 |
| Secondary development | — | ✓ | ✓ | ✓ | ✓ |
| Warranty | 3 months | 6 months + dedicated service | 1 year + dedicated service | 1 year + dedicated service | 1 year + dedicated service |
Figures describe the selected complete-robot version. Complete-robot performance and standalone modules use different measurement bases; “dedicated service” keeps the original wording — ask sales for the exact scope.
Configure and quote
Start from the modules the current task needs. Existing modules carry over to the next task, and software and intelligence stay on one stack, so development effort is not lost when the form changes. Send us the form and version you need and we will quote the configuration, lead time and support scope.



No evaluation data
Have a question? Ask others~
Ask a question